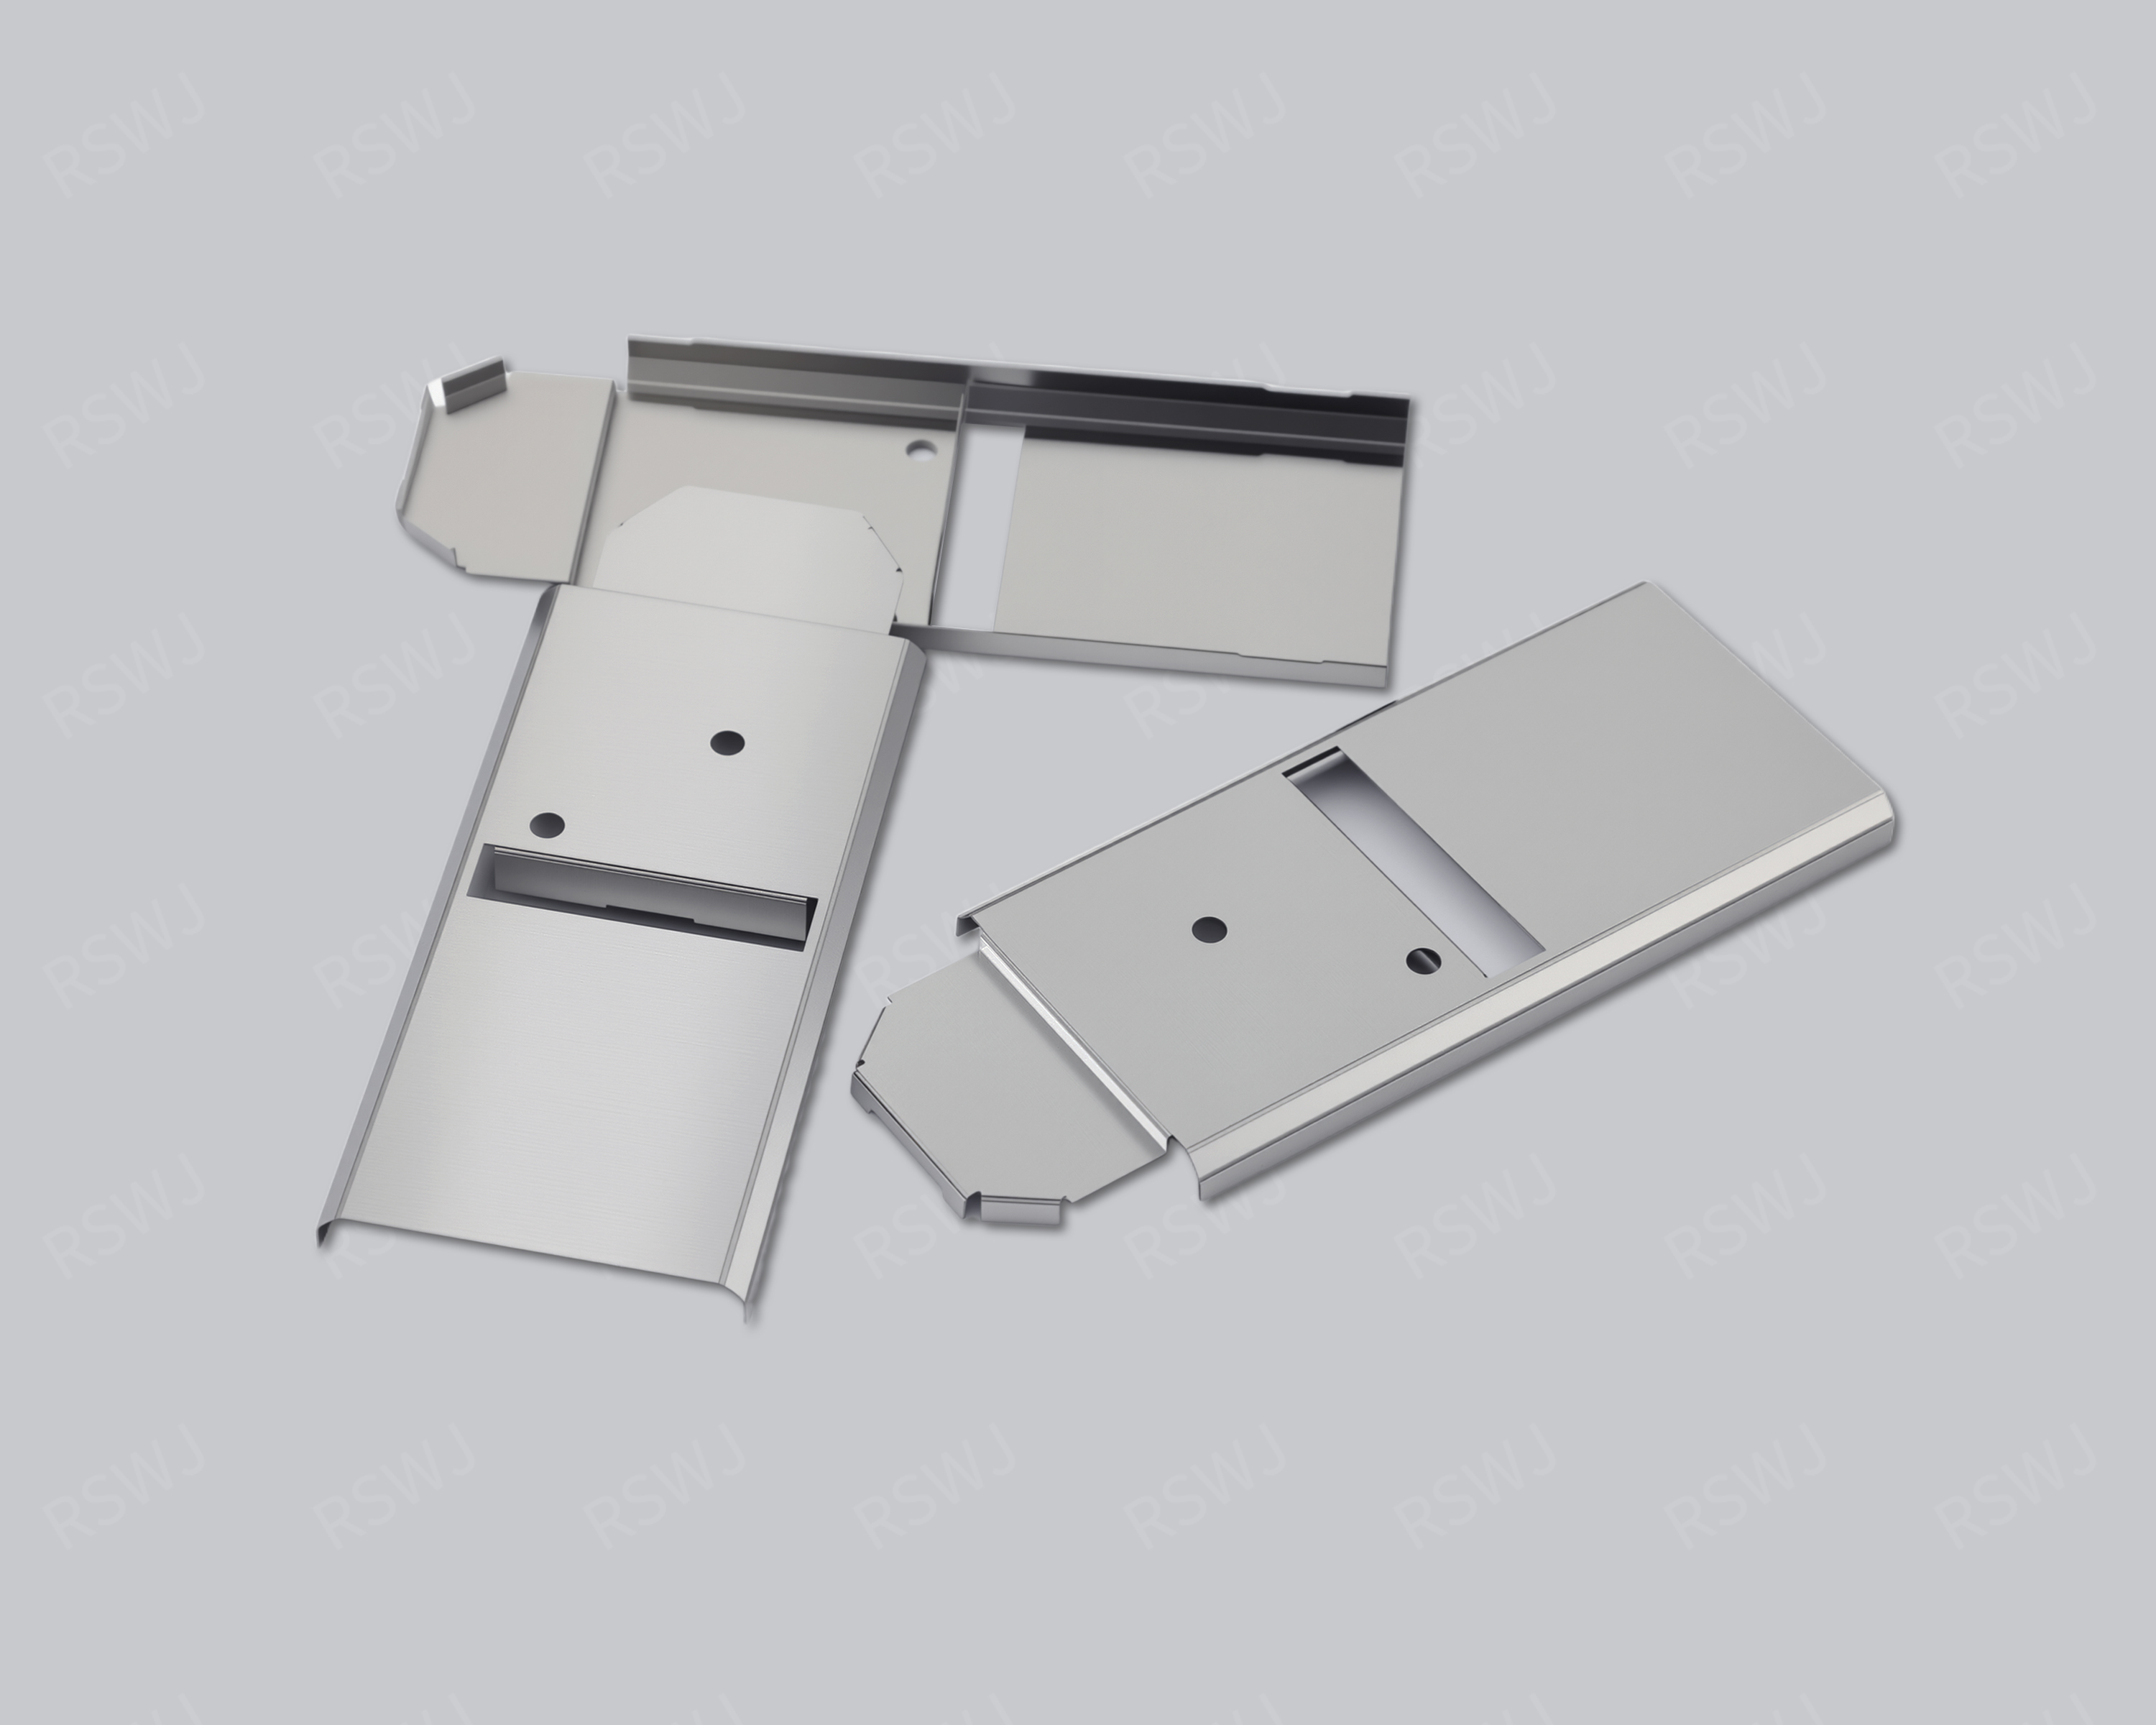
Reference photograph. Material, dimensions and mating requirements are defined in the agreed project drawings.
Equipment motion, harness and fixed datums
A robot electronics shield is reviewed for its control, sensing or drive module and the installed equipment configuration.
| Design focus | Module mounts, harness movement, control interfaces and maintenance positions |
|---|---|
| Project task | Equipment motion, harness and fixed datums |
| Custom inputs | Current drawings, mating parts, material and final surface, quantity and acceptance requirements. |
Equipment motion, harness and fixed datums
Module location, wiring and surrounding structures determine the real boundary. A robot application label does not establish a shared shape or project approval.
For robot electronics, provide the module location, mounts and harness arrangement from the equipment. If motion changes cable position or access, include the relevant installation positions in the structural review. Define the electronic region and the functions involved in the project concern. Trial the sample with real connecting parts, then use customer-defined activity combinations for system evaluation. The robot label alone cannot establish environmental approval, a moving clearance or a validated installed result.
Engineering considerations for this project
Identify what actually moves near the electronics
A robot application should be described through the particular equipment assembly that positions its electronics. Begin with the fixed mounting references for the covered module, then identify any neighboring harness or mechanism that changes position during the customer’s intended operations. Some electronic units remain stationary while only a connected cable moves; others change orientation with the equipment. Those situations impose different clearance and access questions. Distinguishing them prevents a broad robot label from driving an unnecessary feature and gives the cover review a precise relationship between the protected circuit and the surrounding mechanical arrangement.
Represent relevant movement positions using the customer’s mechanical information. Show where a cable is supported, how it approaches the module and whether its routing passes near a shield edge or opening. A flexible cable drawn as a straight line can conceal the space needed for a routed installation. Trial the specified connecting parts with the module in the relevant positions, without assuming an unprovided movement range or environmental requirement. The objective is to locate a credible interaction that engineering can review, not to declare a dynamic clearance from a single view of the cover or a static assembly photograph.
Keep the module’s working datum accessible
Mounting and inspection should refer to the locations that establish the shielded module in the equipment. A convenient edge on the metal can may not be the reference used by the bracket or housing. Identify the functional mounting datum and specify how the cover is checked relative to it. If a surrounding assembly prevents direct access after installation, decide which observations can be made before closure and which require an assembly fixture or a customer-provided mating part. This turns a general fit request into a measurement and placement task that can be repeated during sample approval.
Access for maintenance deserves a separate review from access during the initial build. Determine whether the equipment reaches the module through a service opening, a removable bracket or a defined disassembly sequence. Mark the connections and retention features that must be approached in that state. A cover that can be removed from an isolated board may still be unsuitable for the proposed service direction. Conversely, a fixed cover may be appropriate when the entire module is replaced. Discuss that distinction before selecting closure features so the metal part supports the equipment’s actual maintenance operation rather than a generic expectation of removability.
Tie electronic observations to equipment activity
When the customer’s concern involves sensing, control or a drive-related electronic function, identify the corresponding module and the paths that connect it to other equipment regions. Keep the relevant activity and connection arrangement in the functional comparison. A sample evaluated on an unconnected board cannot automatically describe an installed unit with a different harness and active neighboring functions. Mechanical fit establishes one part of the acceptance decision; the customer’s electronic evaluation establishes another. Reporting them separately helps explain which evidence belongs to the shielding component and which belongs to the complete equipment configuration.
Record changes to the module bracket, harness restraint and cover geometry as distinguishable revisions. A revised restraint can alter the approach of a cable even if the metal drawing is unchanged, while a new opening can affect routing without moving the module. Repeat the checks that correspond to the changed interface, retaining the appropriate equipment positions and mating parts. These inputs support a focused manufacturing discussion for robot electronics. They do not infer a motion endurance result, environmental rating or safety approval from the product name; any such requirement must come from the customer’s defined equipment specification and validation plan.
Boundary, clearance and mating design
Mark cable movement, mounts and interfaces from the equipment assembly. Separate any sensing or communication region that needs functional space from electronic coverage.
Translate the application into an actual circuit region. Mark the devices, interfaces and surrounding functions involved in the project concern. The equipment name can help organize discussion, but it does not provide hidden dimensions, compatibility or operating performance. Identify what must remain outside the metal boundary, such as a functional antenna, optical region or connection operation. The perimeter then follows a defined electronic and mechanical task rather than an arbitrary rectangle around the board.
Material and final surface definition
Select the material and final surface through forming, attachment, contact and the customer environment. The application label does not determine an alloy or coating for the reference. Specify grade, condition and thickness where required, with the final treatment separate. A working cover edge and a board joining region may need different checks. If a material alternative is evaluated, keep its changed conditions clear instead of treating it as an interchangeable color or marketing designation.
Forming and the installation sequence
Review attachment and maintenance using the actual housing and connected harness. If motion affects access or wiring, include the relevant installation positions.
Use the real mounting references and component envelopes to establish fit. Review the path used to place the shield, connect interfaces and fit the surrounding housing. The final position can clear a connector while the required insertion motion remains blocked. Mark intentional contacts separately from required gaps. When another part loads the roof, check the installed state rather than using an unloaded cover height as the full clearance decision.
Motion and wiring belong in the installation definition
Compare module-cover concepts with equipment mounts and harness conditions. If an operating position changes cable placement or maintenance access, identify it in the review. Keep the control, sensing or drive region clear and preserve any relevant functional exclusions. Trial the corresponding housing and connecting parts. The robot application provides an integration topic but does not establish material durability, vibration approval or a system result for the catalog reference.
Part inspection and application evaluation
Use project-defined combinations of control, sensing and drive activity. Record the installed contact and harness arrangement with the board and shield version.
A drawing package for this custom part
| Input | What makes it usable |
|---|---|
| Coverage & interfaces | Module mounts, harness movement, control interfaces and maintenance positions. Mark their relationship with the actual circuit or mating layout; identify fixed references and permitted changes. |
| Final part & datums | A dimensioned finished-part drawing and available 3D information. Identify functional dimensions, the installed condition and the measurement references used to accept them. |
| Material & surface | The specified grade, condition, thickness and final treatment. Show contact, joining and insulated regions separately; identify any alternative that needs evaluation. |
| Assembly & acceptance | Corresponding mating revisions and the installation or access sequence. Distinguish part inspection, matched fit and customer system checks with their agreed conditions. |
Questions for this design review
Which operating information helps the sample plan?
State the module location and the activity combinations relevant to the customer concern, along with wiring and installation positions. Separate mechanical access from project system comparison. Record the fixed datums and actual contact arrangement. This makes observations repeatable and allows a shield revision to be evaluated against the intended equipment configuration rather than an isolated module with different surrounding parts.
Which drawings support the review of Robot Electronics Shielding Can?
Use the current layout and mating assembly to identify module mounts, harness movement, control interfaces and maintenance positions. Mark the relationship that is already fixed and the specific feature being considered for change. A drawing of the cover alone may omit the condition that gives the reference its engineering purpose. Include the corresponding board or base and the intended operation so the proposed revision can be evaluated against a defined task rather than a similar-looking external shape.
In-House Tooling & Formed-Part Quality
Tooling development and forming quality
The manufacturing review for Robot Electronics Shielding Can connects how critical features are formed, how they are inspected and how they meet the mating assembly. Ruishuo links in-house die design and CAD/CAM simulation with stamping. Die-making output of more than 100 sets per month is a factory capability; the tool concept is reviewed for the actual project.
Fixing interfaces and inspection access
Equipment-module tooling review needs the fixing surfaces, ports and service operations. Formed attachment features and openings require practical measuring datums. Define sensor, signal and maintenance keep-outs in the complete assembly information.
- Fixing and functional space
- Agree how critical features are measured and installed. Keep the functional space requirements with the finished drawing.
- Part checks and project acceptance
- Assess dimensions and fit against the drawing. Industry or equipment-level system testing follows the customer-defined method and scope.
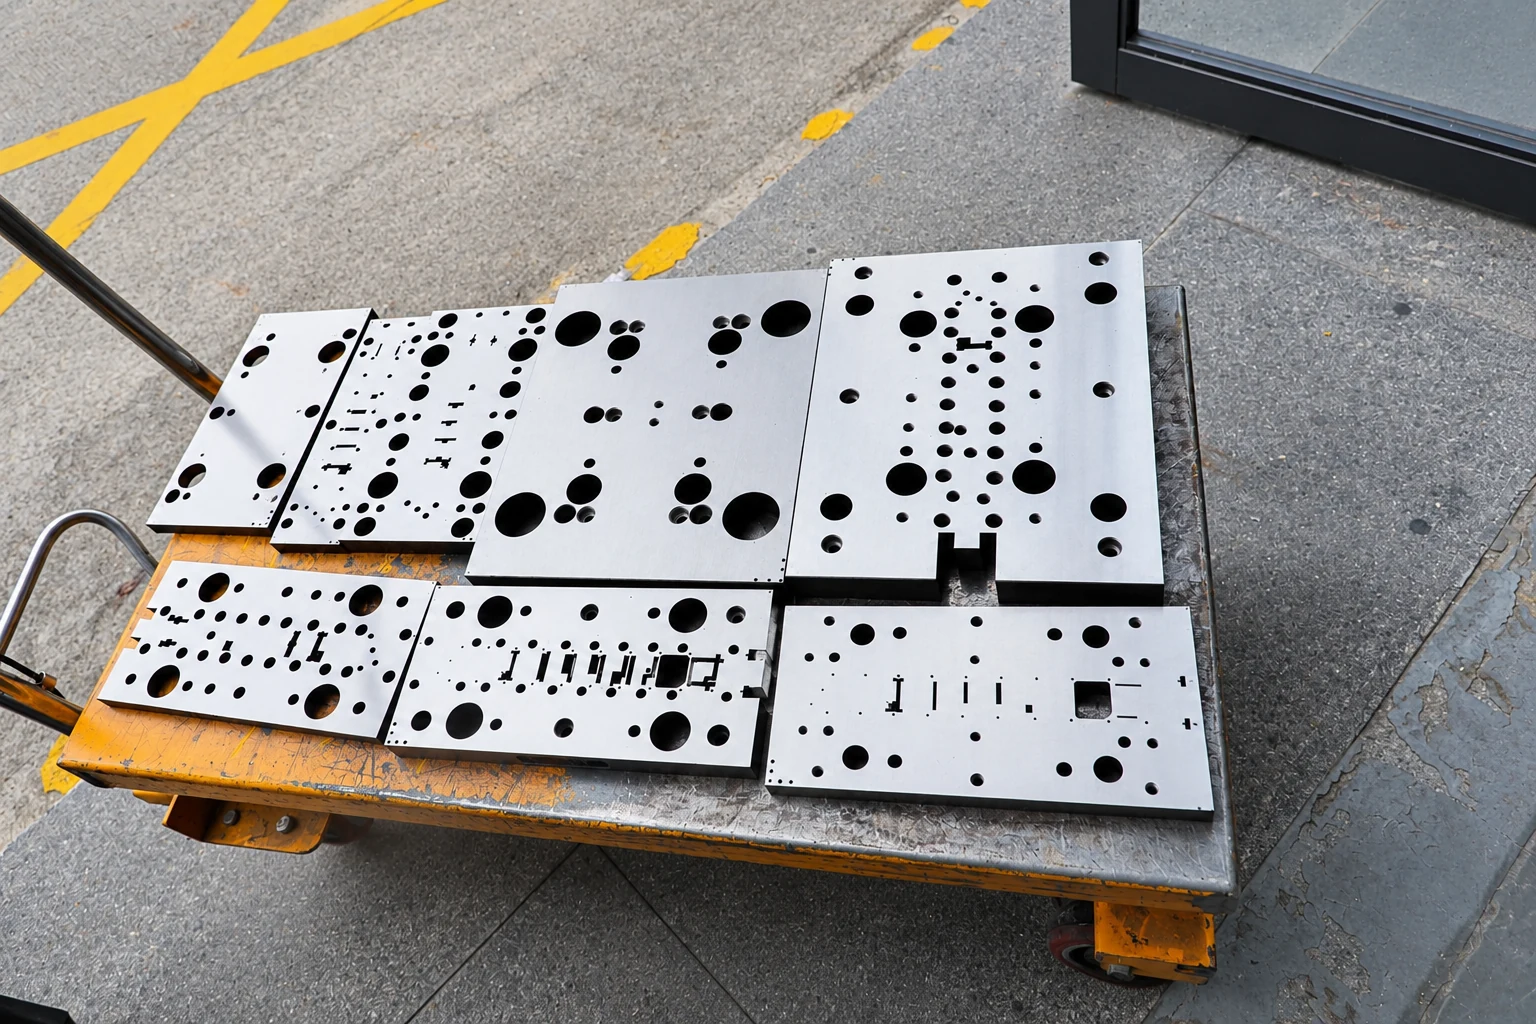
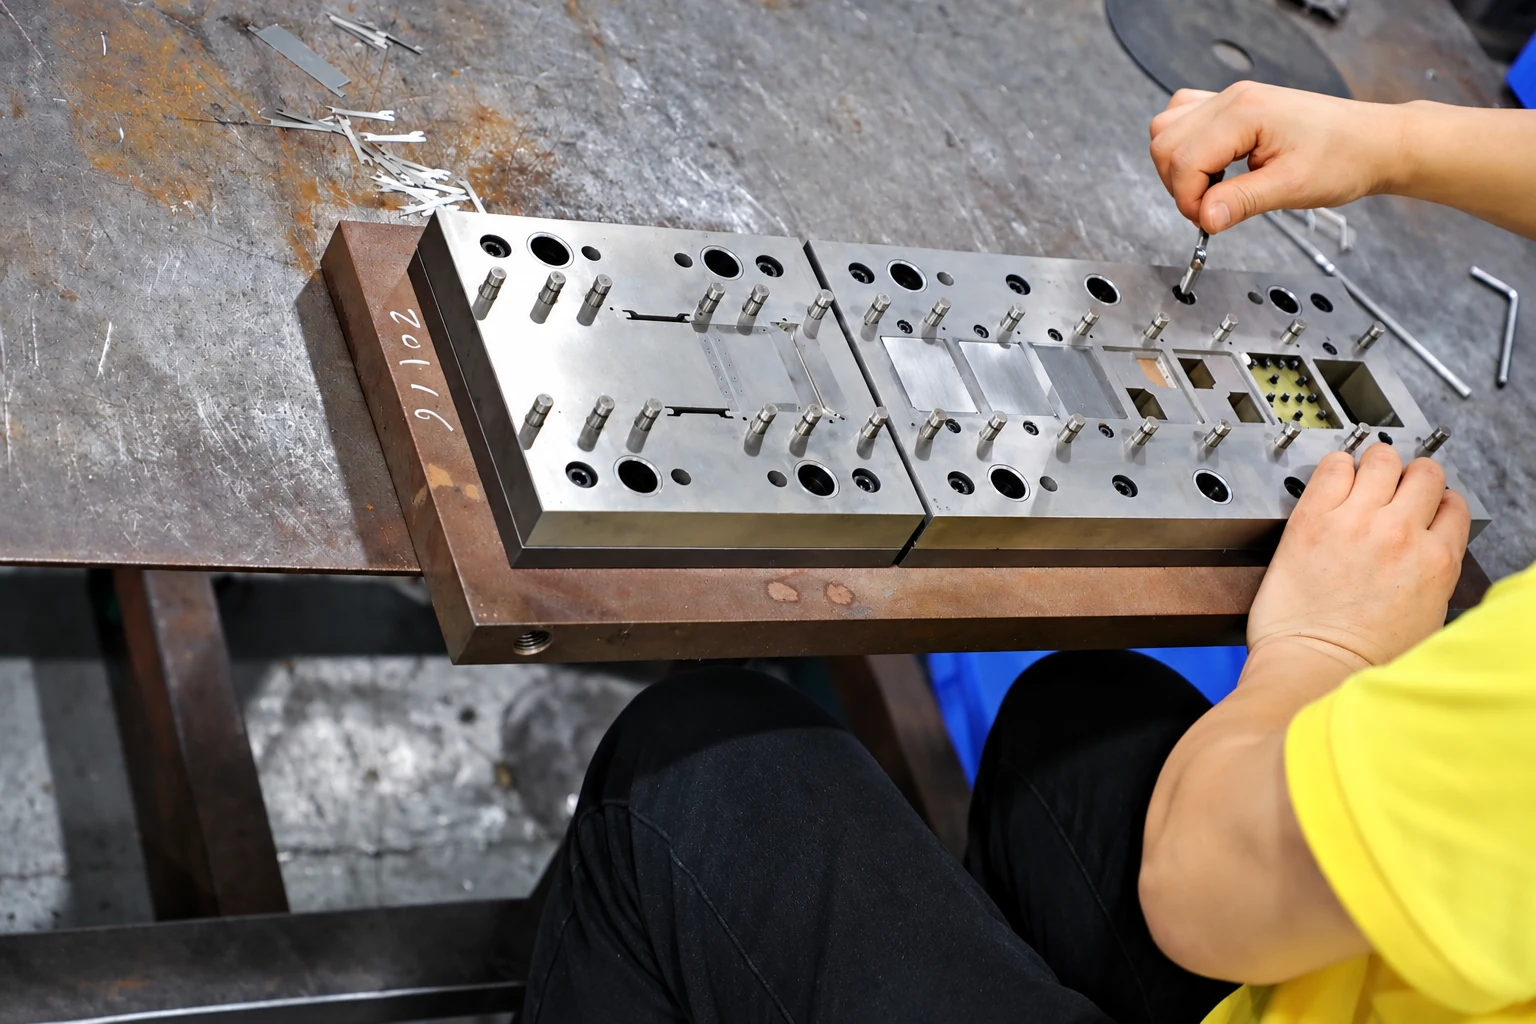
Paid samples include a full dimensional inspection report. Define drawing datums, acceptance criteria and corresponding mating parts so measurement and installed-fit checks can each answer the correct question. Confirm the charges, responsibilities and revision requirements for design changes, tooling work and later production stages within the project scope.
Paid samples and project planning
Samples are chargeable. Reference planning: standard samples 3–5 days; expedited sampling 48 hours; tooling and sample production 7–10 days. These are sample-stage arrangements, excluding mass-production delivery. The project plan is reviewed against the confirmed information, process and sample scope.
Related structures and project directions
Compare references through their coverage, installation and manufacturing tasks.
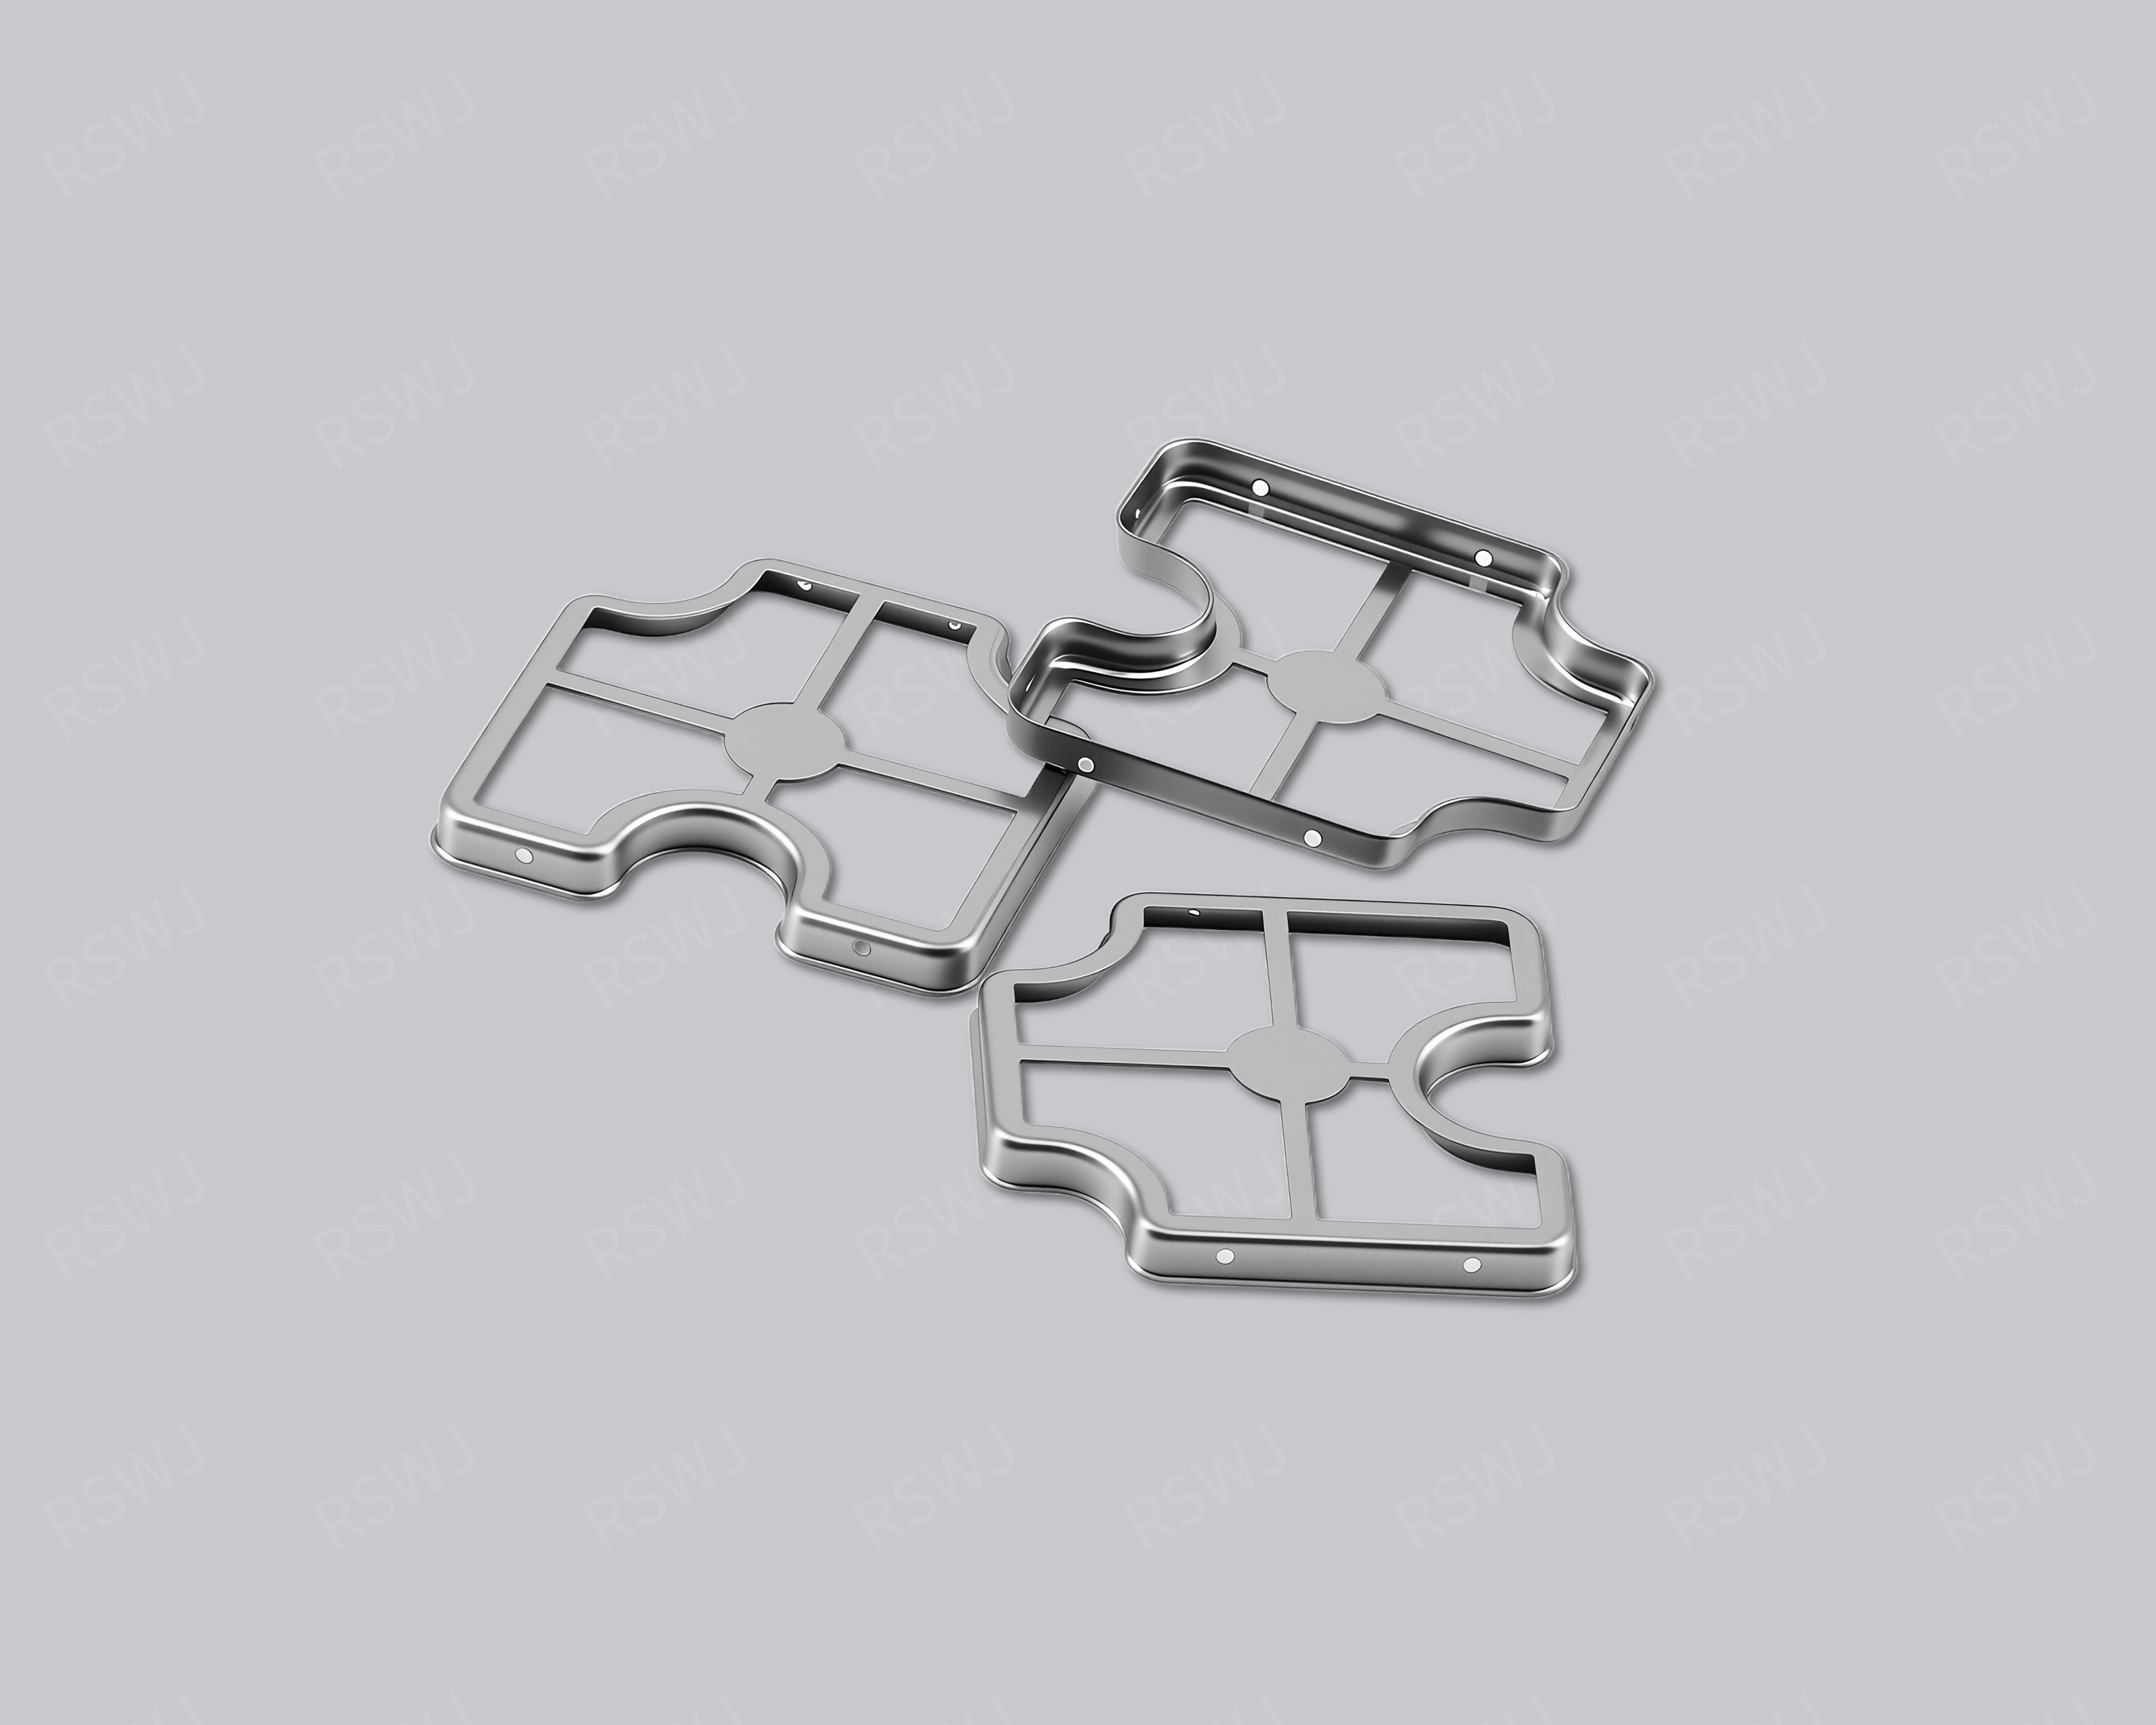
5G Circuit Shielding Can
A 5G shielding can is designed around a specified communication circuit region and its integration conditions.
Design & manufacturing details →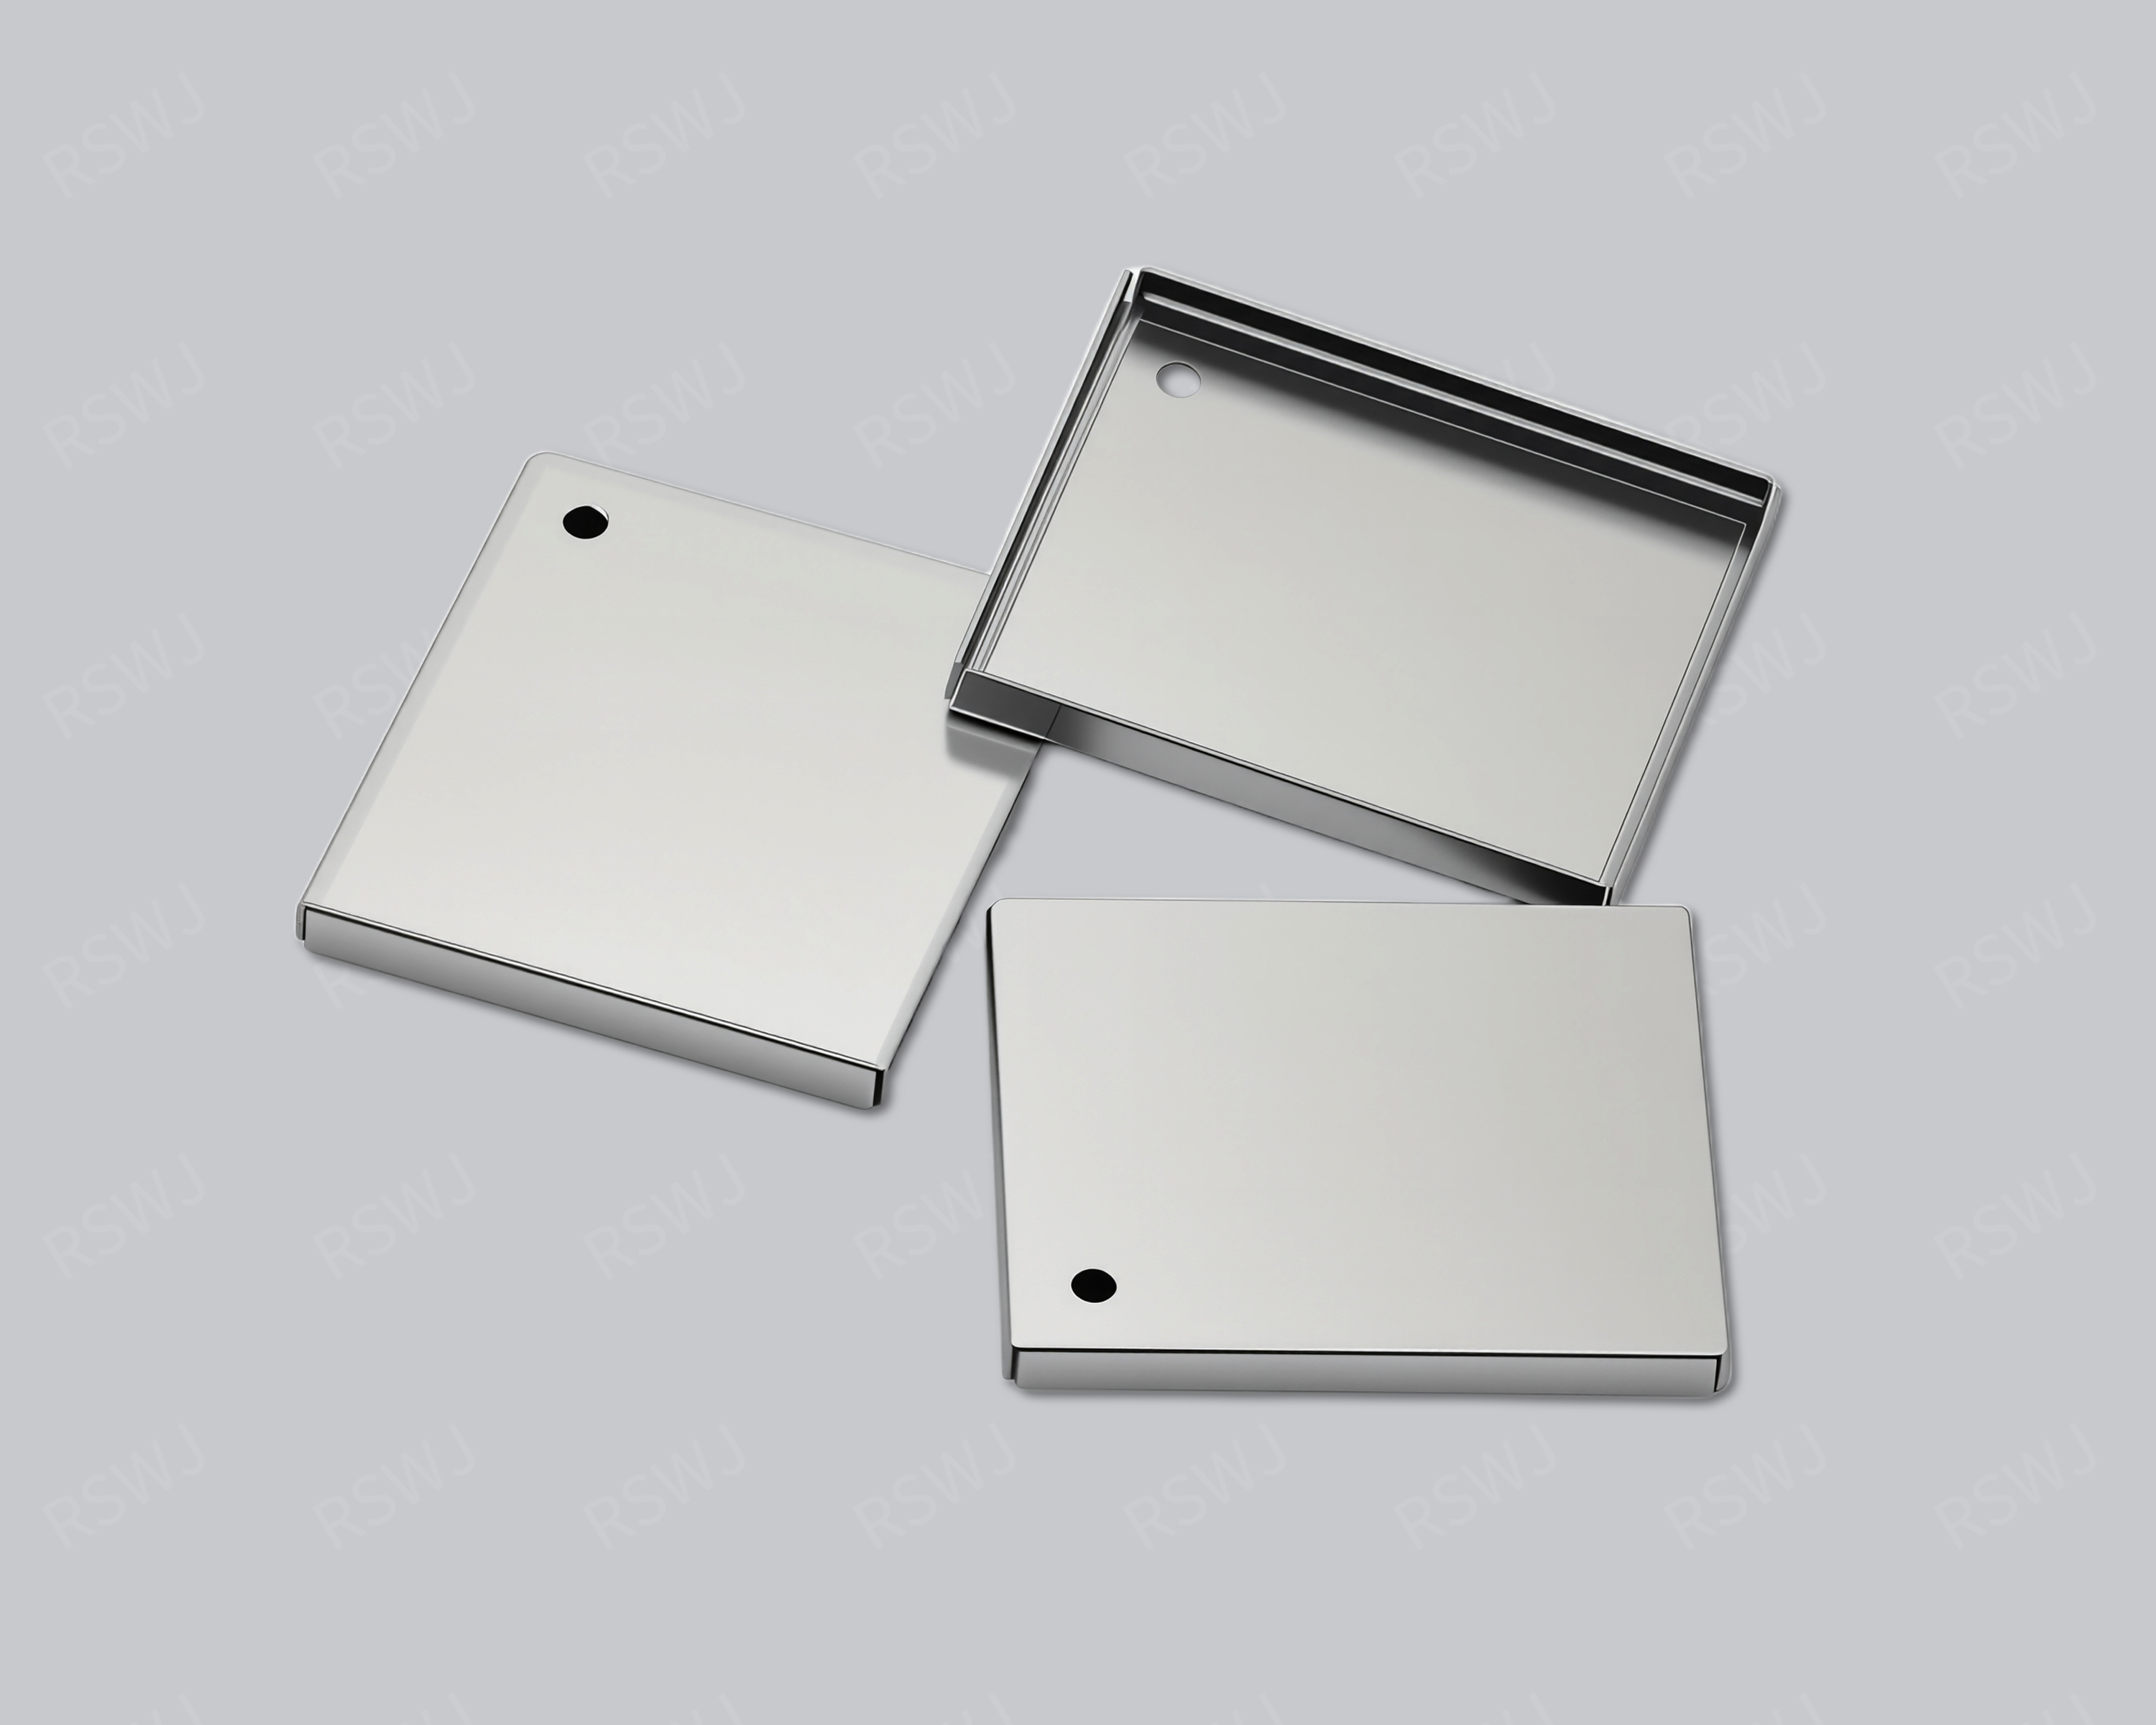
5G Module Shielding Can
A 5G shielding can is designed around a specified communication circuit region and its integration conditions.
Design & manufacturing details →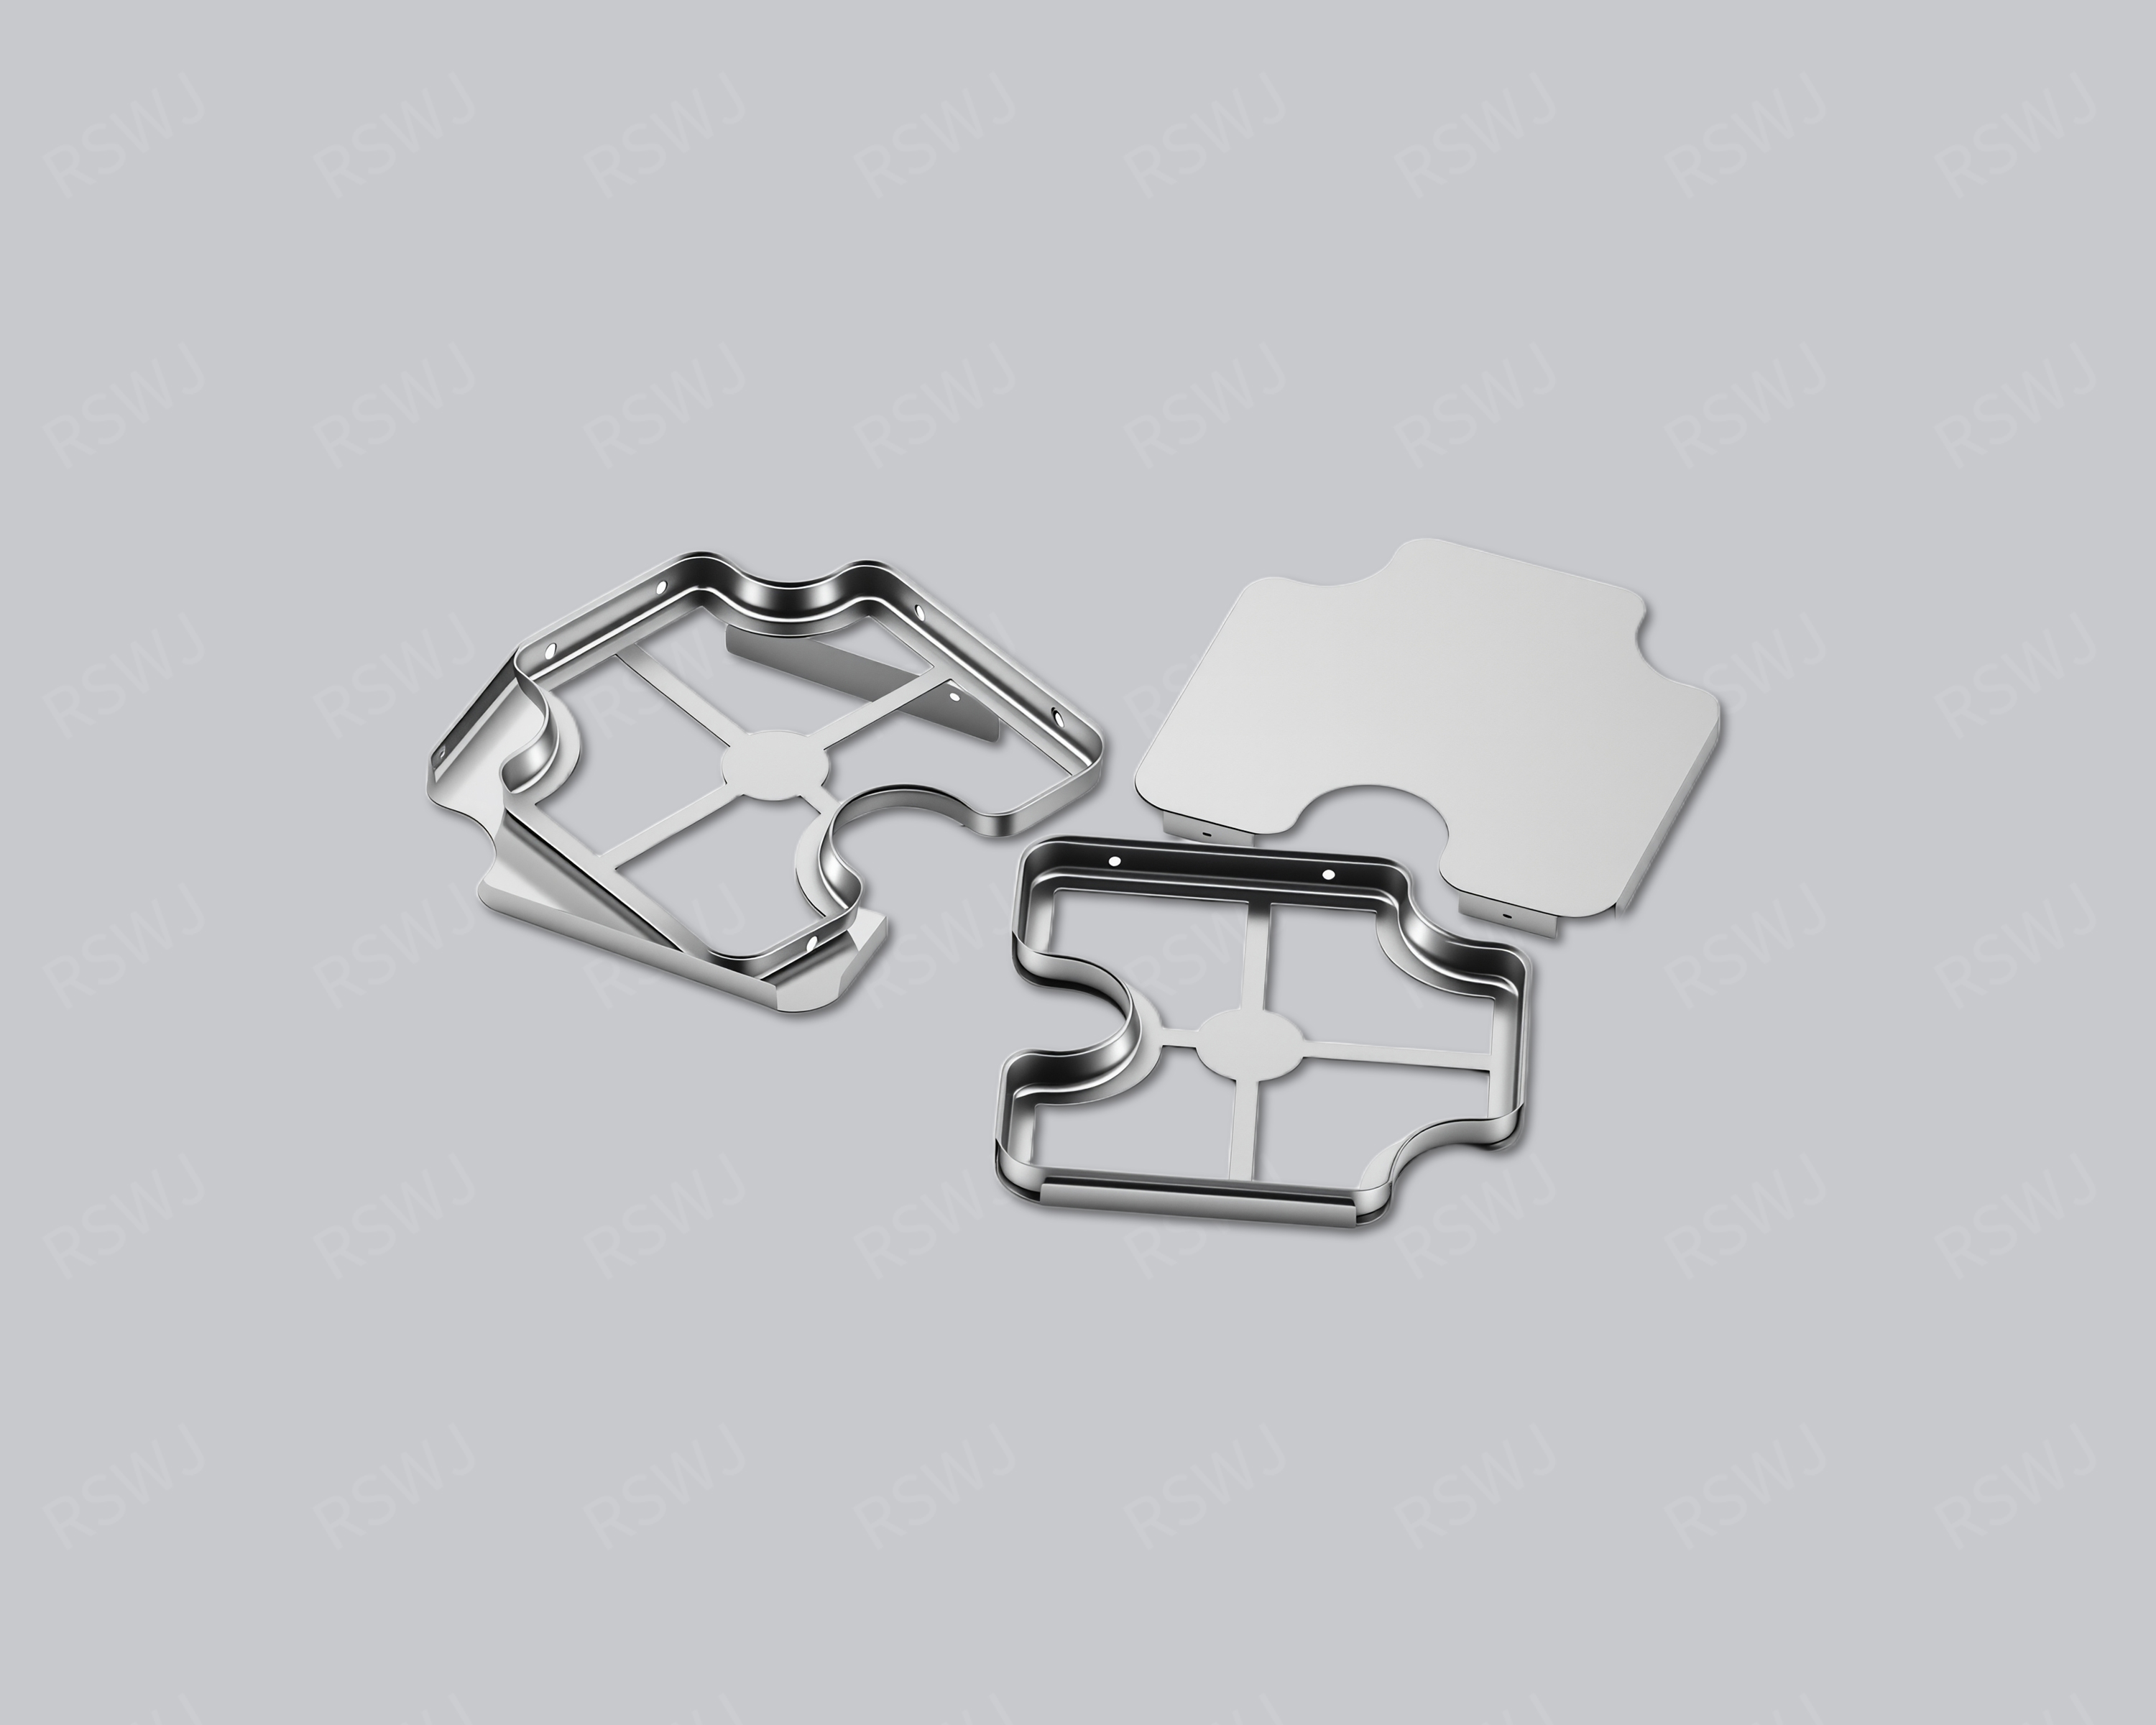
ADAS Module Shielding Can
An ADAS module shield is reviewed around the specific sensing, processing or communication circuit requiring coverage.
Design & manufacturing details →Discuss your Robot Electronics Shielding Can project
Send the current drawing and mating conditions so we can review the structure, material, sample scope and required checks.
Send your project requirementsExplore electronic applications